 Meet MarshGazers
UCL East / 2024–25 / Olympus Rover Trials Basic Stream
Olympus Basic
A first rover. A shared ambition.
01 / The mission
A camera on Mars. A team finding its feet.
The challenge was visual reconnaissance: drive a rover through an analogue Martian crater, reach five points of interest and capture the smallest readable QR codes. A live view connected the operator to a vehicle they could not stand beside.
02 / Our starting point
Building our first entry.
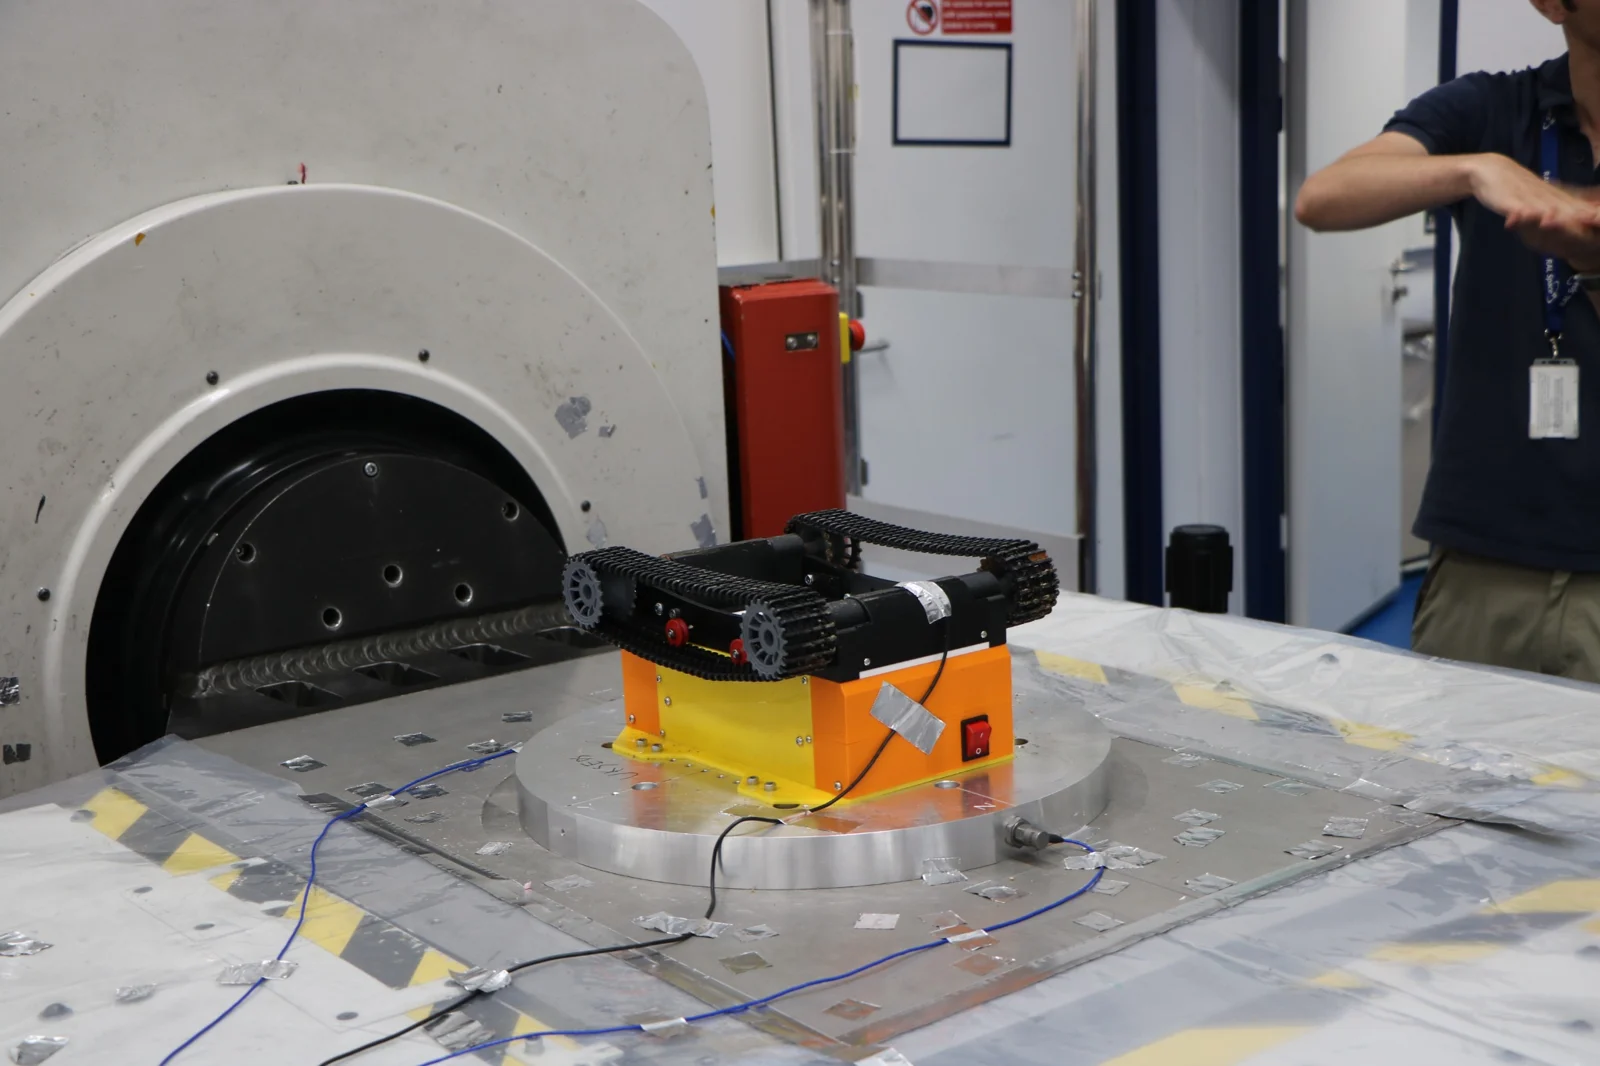
Nine UCL East students came together to put their robotics skills to the test. For our first Olympus Rover Trials entry, we chose an effective, teleoperated reconnaissance rover: tracked mobility, a movable camera and a control interface that brought the mission back to the operator.
My part in the team.
Fahd Adel captained our first competition season. I contributed to the mechanical platform, the camera arm and the operator-facing control system, working with the team to connect hardware, image collection and remote operation.
03 / Engineering the mission
See clearly. Move reliably.
Grip the terrain.
Tracks were chosen for traction on the gravel course. Differential steering let the rover turn on the spot, keeping the mobility system compact and manoeuvrable.
Look beyond the chassis.
A two-revolute-joint camera arm provided two degrees of freedom for aiming at inclined QR codes. A forward-facing camera gave the operator a view of the route ahead.
Keep the operator connected.
I supported Arduino-based Wi-Fi control and developed an HTML and JavaScript operator interface, alongside QR detection work using Nicla Vision, MicroPython and OpenMV. Driving remained teleoperated.
04 / From team to terrain
The build, frame by frame.
Follow the hardware, preparation and competition story. Select a frame for the closer look.
01 / 06
05 / What we took forward
An award-winning first season.
Our first entry placed second nationally and received the Best Automation and Best Outreach awards. The season also established a team, a way of working and a foundation for a more ambitious rover.
What the season taught us.
The title of an automation award does not change the rover's operating mode: this was a teleoperated vehicle. The broader lesson was how mechanical decisions, camera placement and interface design shape the same mission together.